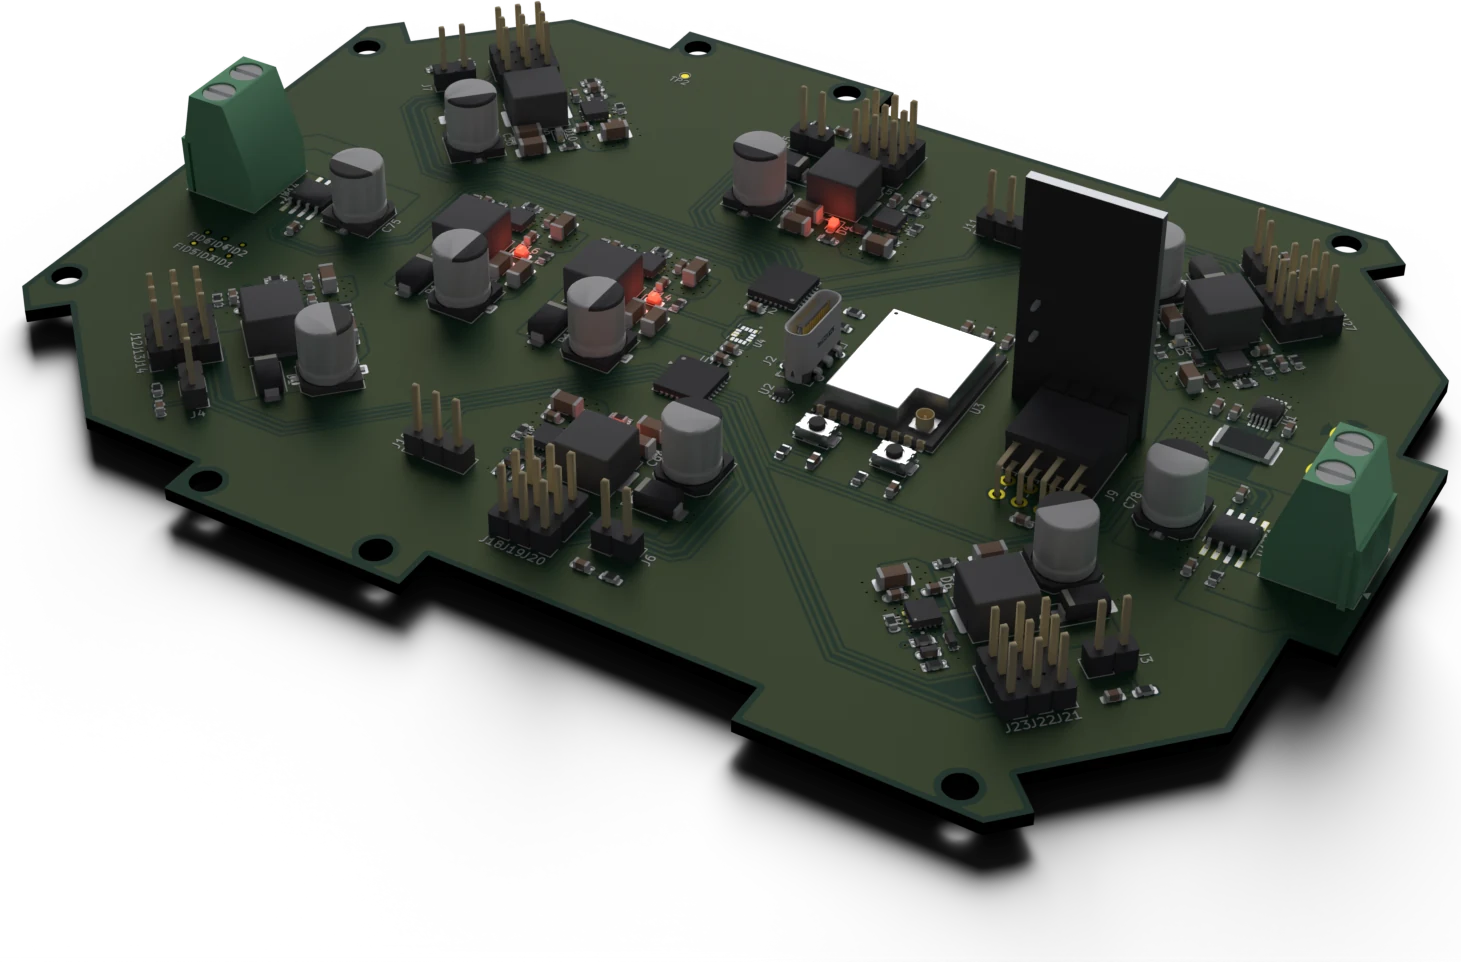
Overview
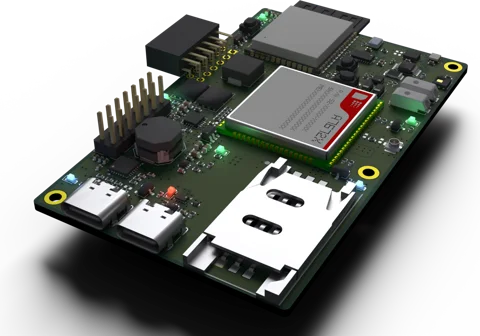
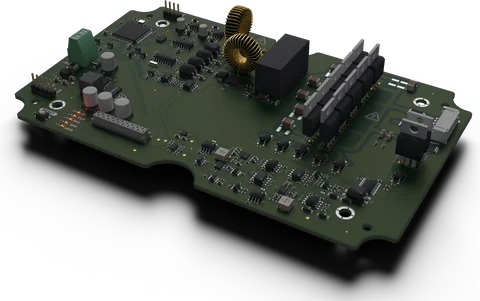
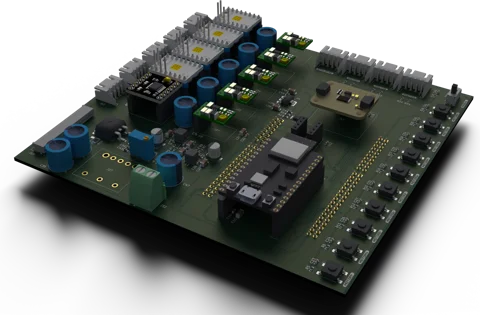
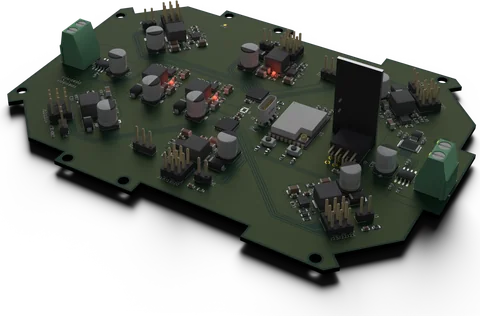
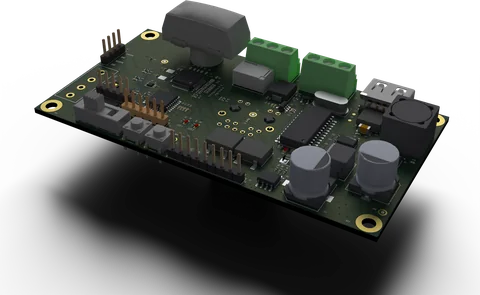
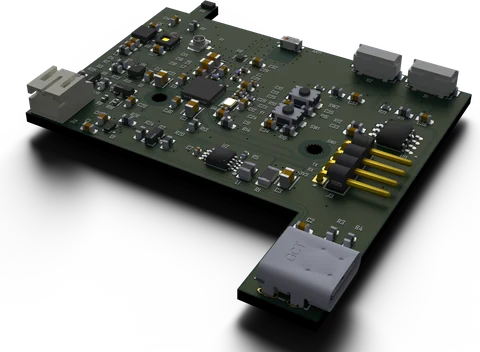
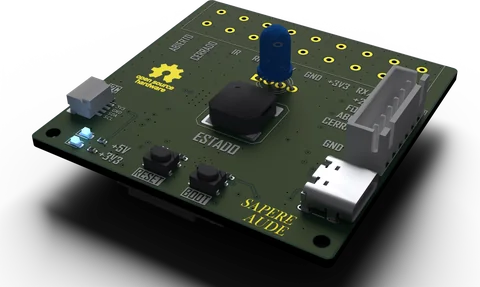
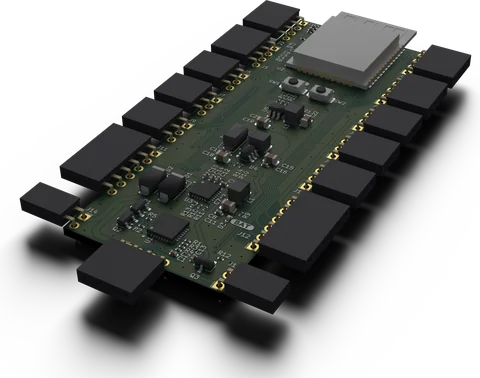
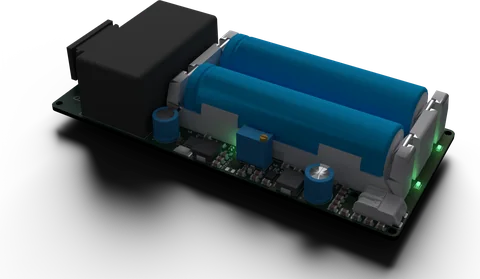
Control board for a multi-joint robot. Eight 6 A buck converters power groups of servos driven by PWM from two PCA9685s; an ESP32-C3 runs the board, reads the IMU and limit switches, drives two DC motors and talks over a 2.4 GHz radio.
Design challenges solved
- High-current distribution from battery: eight 6 A buck rails with per-rail TVS.
- System current and energy metering with an INA228.
- 20 servo outputs, 6 limit-switch inputs and 2 H-bridges on a single board.